A portable K-band FMCW radar that locates targets in three dimensions: range, azimuth, and elevation. It uses MIMO, where every transmitter–receiver pair acts as one element of a much larger virtual array, so a modest number of channels gives the angular resolution of a far bigger antenna.
Spreading antennas far apart usually creates grating lobes, false beams pointing in the wrong direction. This radar avoids them with a non-uniformly spaced array whose element positions and weights I optimized. A calibration procedure aligns the phase and amplitude of every virtual element. The full design and signal processing are described in my Ph.D. dissertation.
- Frequency
- 24 GHz (K-band) FMCW
- Antennas
- 16 Tx and 16 Rx, non-uniformly spaced around a square
- Design resolution
- 3° in azimuth and elevation
- Field of view
- 90° horizontal and vertical
- Data link
- Wi-Fi to a laptop
System Design
RF board · baseband board · Wi-Fi board
RF board
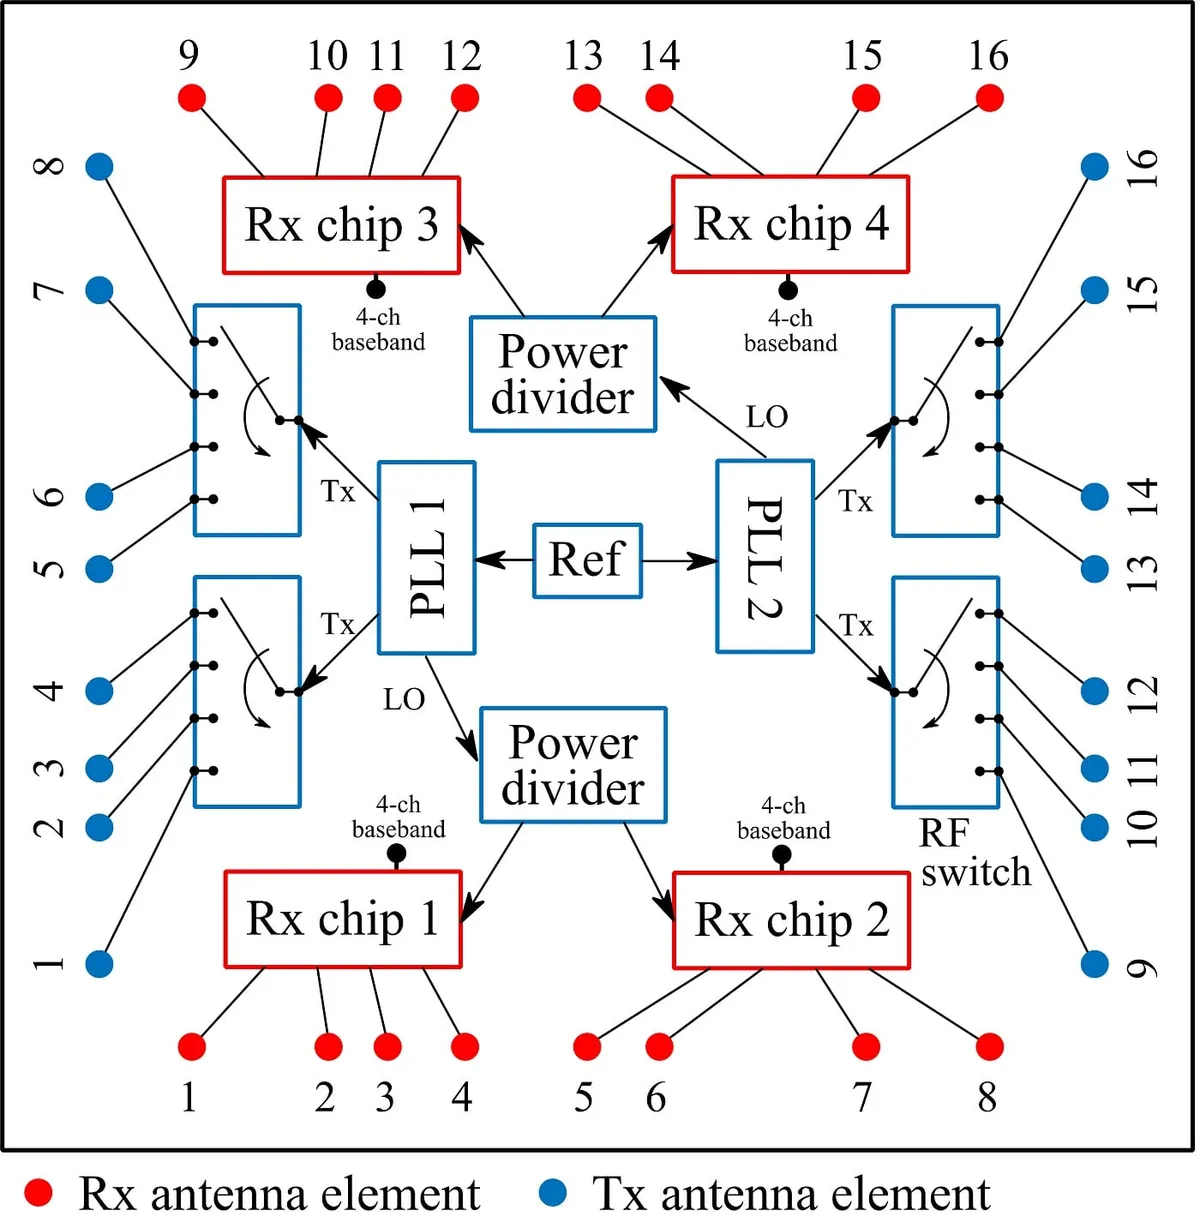
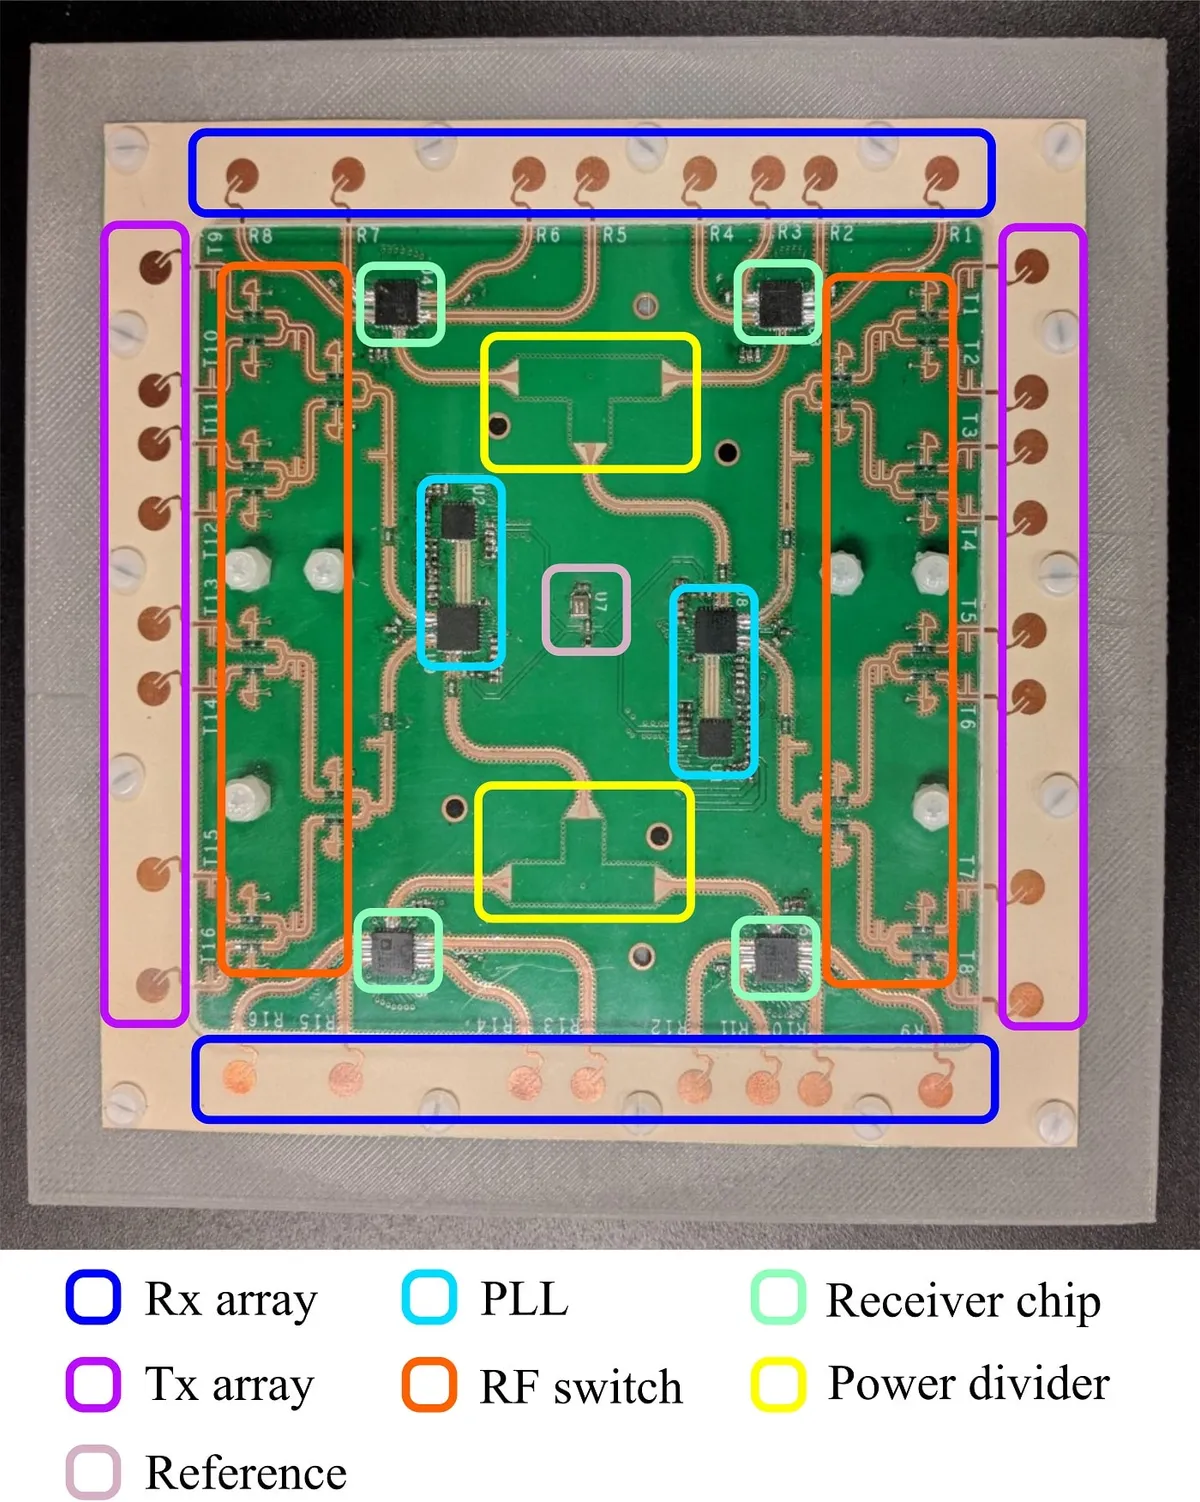
On the transmit side, two PLLs share one reference clock. Each PLL has an LO output and two Tx outputs, all switched on and off independently. Every Tx output drives a custom single-pole-four-throw (SP4T) switch that selects one of four transmit antennas, so 4 Tx outputs reach all 16 transmit antennas.
On the receive side, four radar receiver chips with four channels each provide 16 receive channels. Two of the chips take their LO from PLL 1 and the other two from PLL 2.
The 16 transmit and 16 receive antennas sit along the edges of a square (Fig. 2). Their unequal spacing narrows the beam while keeping grating lobes away, giving a designed resolution of 3° over a 90° field of view in both planes.
Baseband and Wi-Fi
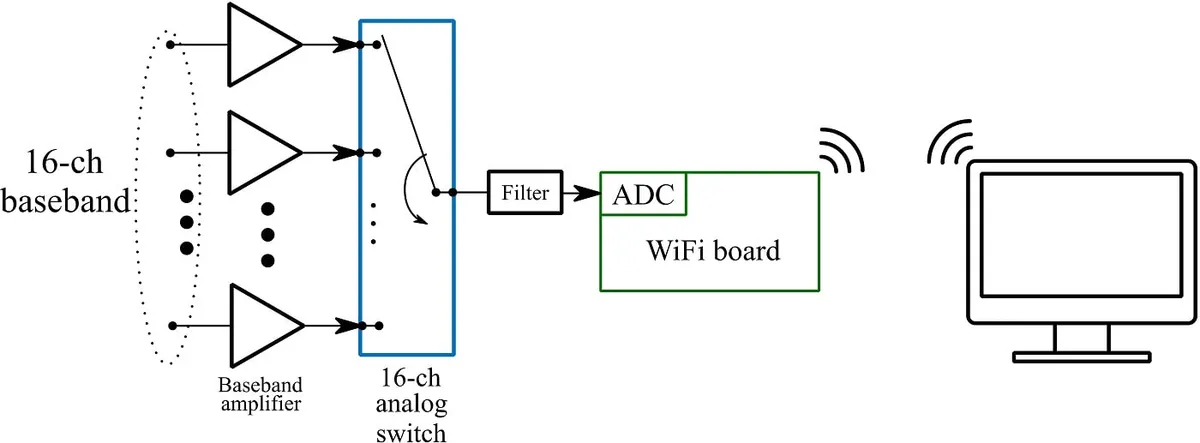
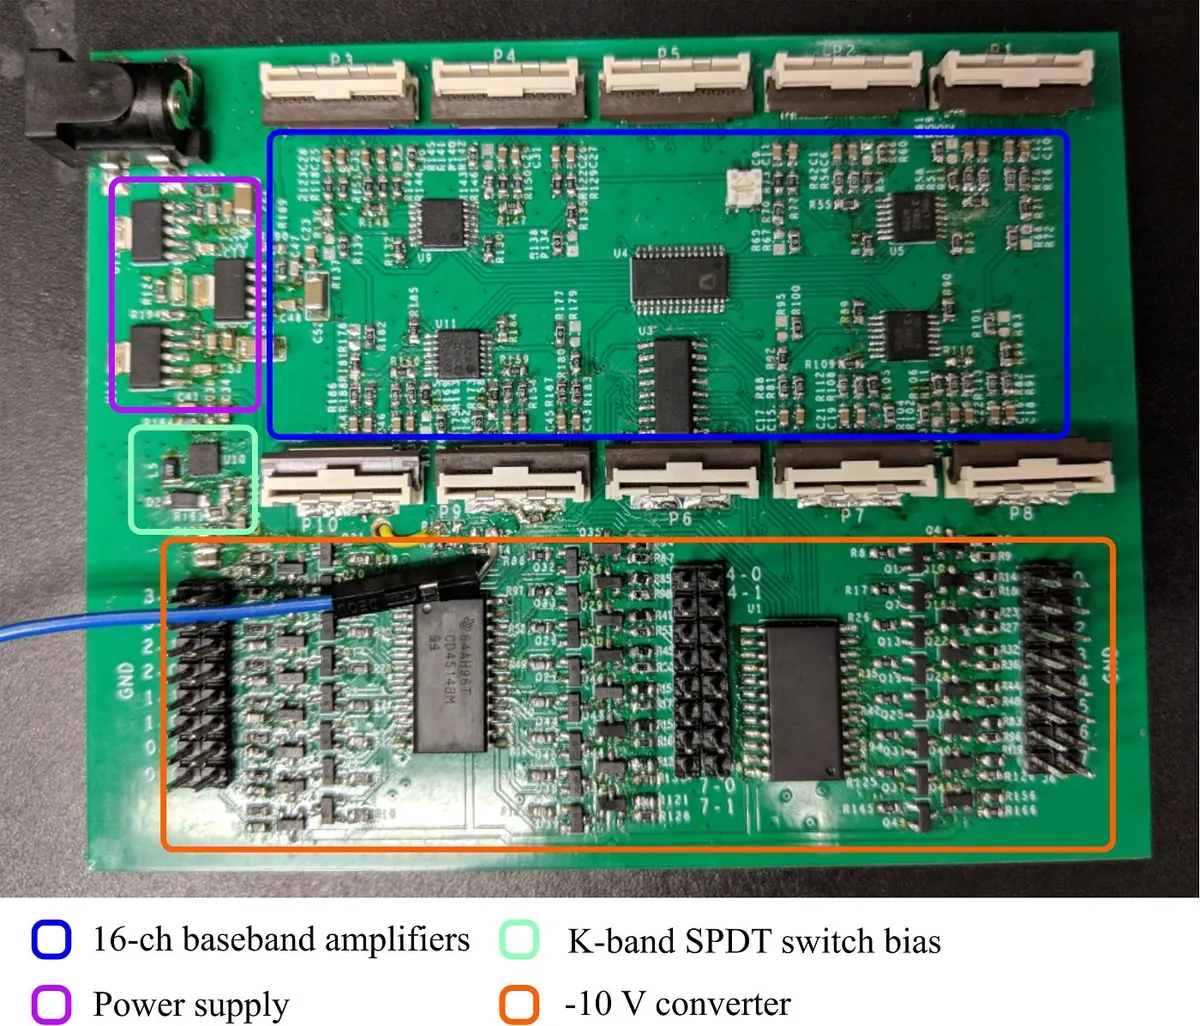
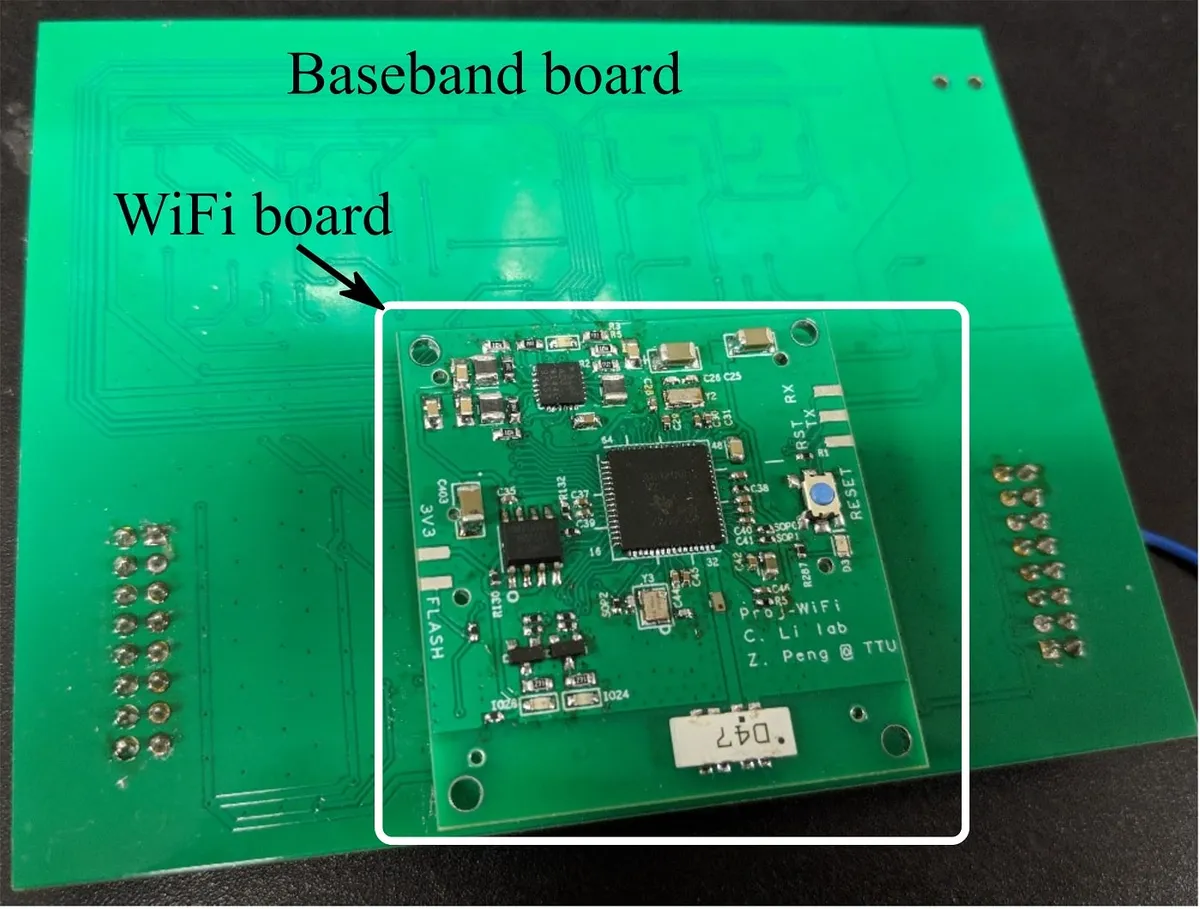
Sixteen baseband amplifiers condition the 16 receive channels (Fig. 3). An analog switch then picks one channel at a time for the ADC on a Wi-Fi board, which sends the samples to a computer for processing. The microcontroller on that Wi-Fi board also controls everything else on the RF and baseband boards.
Prototype
RF, baseband, and Wi-Fi boards
The RF board (Fig. 4) follows the layout in Fig. 2. It is built on 0.254-mm Rogers RO3003, measures 120 × 120 mm, and sits on a 3D-printed frame.
The front of the baseband board (Fig. 5) holds the power supply, the 16 baseband amplifiers, bias circuits for the K-band switches, and a −10 V converter. The Wi-Fi board is stacked on the back (Fig. 6). Its main chip, a TI CC3200, combines an ARM microcontroller, a Wi-Fi subsystem, and an ADC that samples at up to 250 ksps.
| Board | Function | Part | Manufacturer |
|---|---|---|---|
| RF board | Clock | 520L15IA40M0000 | CTS |
| PLL | ADF4159 | Analog Devices | |
| VCO | ADF5901 | Analog Devices | |
| Receiver | ADF5904 | Analog Devices | |
| PIN diode | MADP-000907-14020W | MACOM | |
| Baseband board | Regulator | TPS7A4501DCQR | Texas Instruments |
| DC-DC converter | TPS63700 | Texas Instruments | |
| Decoder | CD74AC138 | Texas Instruments | |
| Decoder | CD4514B | Texas Instruments | |
| Op amp | ADA4851 | Analog Devices | |
| Analog switch | ADG706 | Analog Devices | |
| Wi-Fi board | Wi-Fi and ARM MCU | CC3200 | Texas Instruments |
| Filter | DEA162450BT | TDK | |
| Antenna | AH104F | Taiyo Yuden | |
| DC-DC converter | ADP5135 | Analog Devices | |
| Flash | AT25SF161 | Adesto |
Experiment
Three corner reflectors in 3D
Locating targets in range, azimuth, and elevation
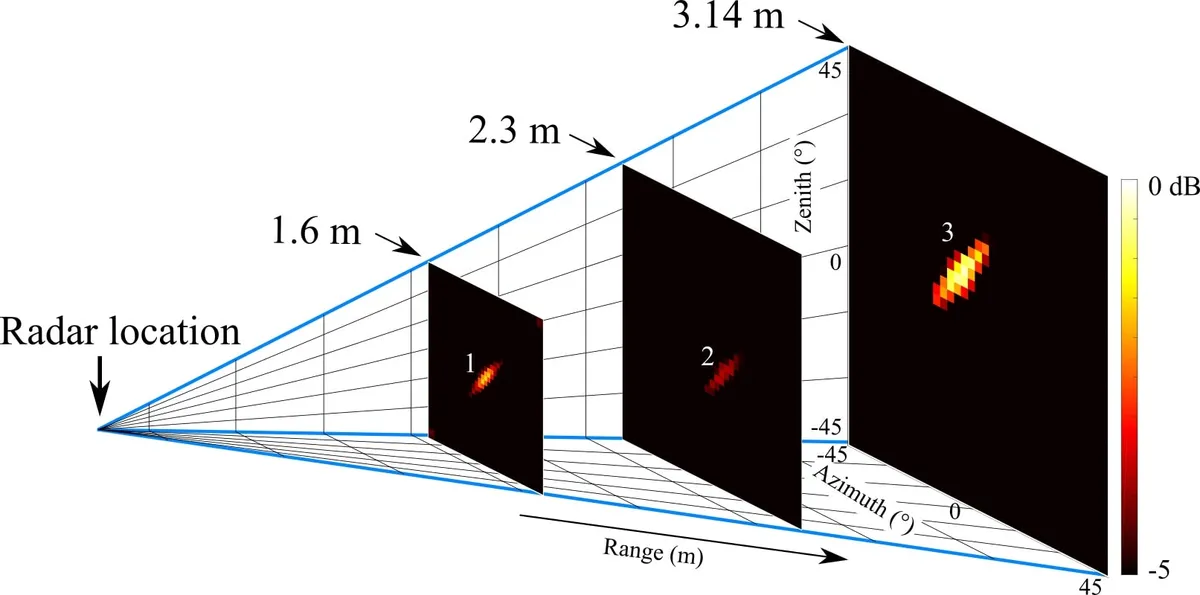
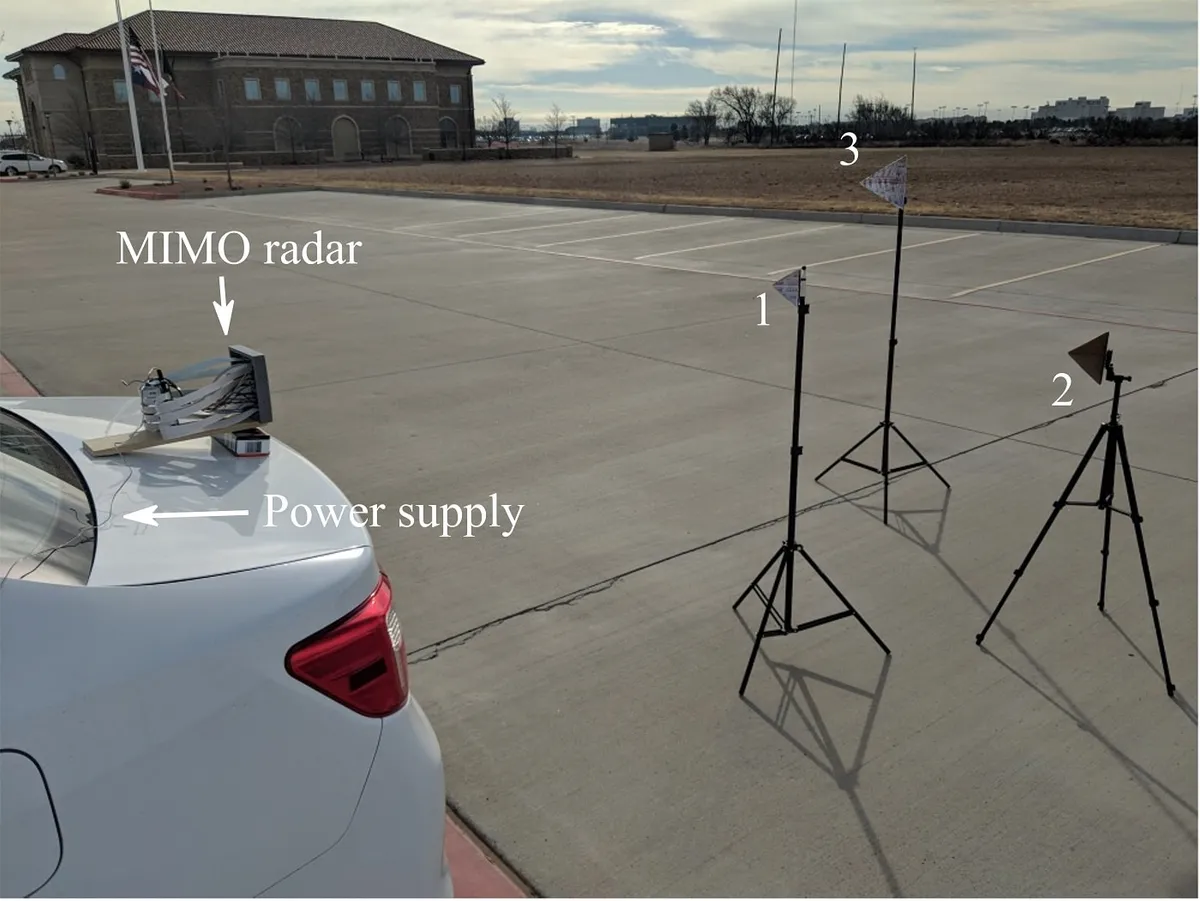
I tested the radar in an open area to avoid multipath. The radar sat on a car, powered from the cigarette lighter, and a laptop inside the car recorded its data over Wi-Fi. Three corner reflectors stood in front of it at different ranges and heights (Fig. 7).
In this prototype, 8 of the 16 transmit antennas and 8 of the 16 receive antennas were working, which gives 64 transmit–receive channels. That was enough for 3D imaging. After calibration, the radar placed the three reflectors at 1.6 m, 2.3 m, and 3.14 m, each at its own azimuth and elevation (Fig. 1).
Publication
Where this work appeared
- A portable K-band 3-D MIMO radar with nonuniformly spaced array for short-range localizationZ. Peng and C. LiJournalIEEE Transactions on Microwave Theory and Techniques, vol. 66, no. 11, pp. 5075–5086, Nov. 2018
Archived comments
Comments left on the previous version of this site.
Hi. I like your work! And the way you have documented it! I found this through your radar simulation. Thanks!
The combination of 24 GHz sensing and 3D MIMO makes radar much more than a simple distance-measuring system. A portable design is particularly interesting because spatial information can be captured in a compact platform, opening possibilities for more flexible real-world sensing applications.