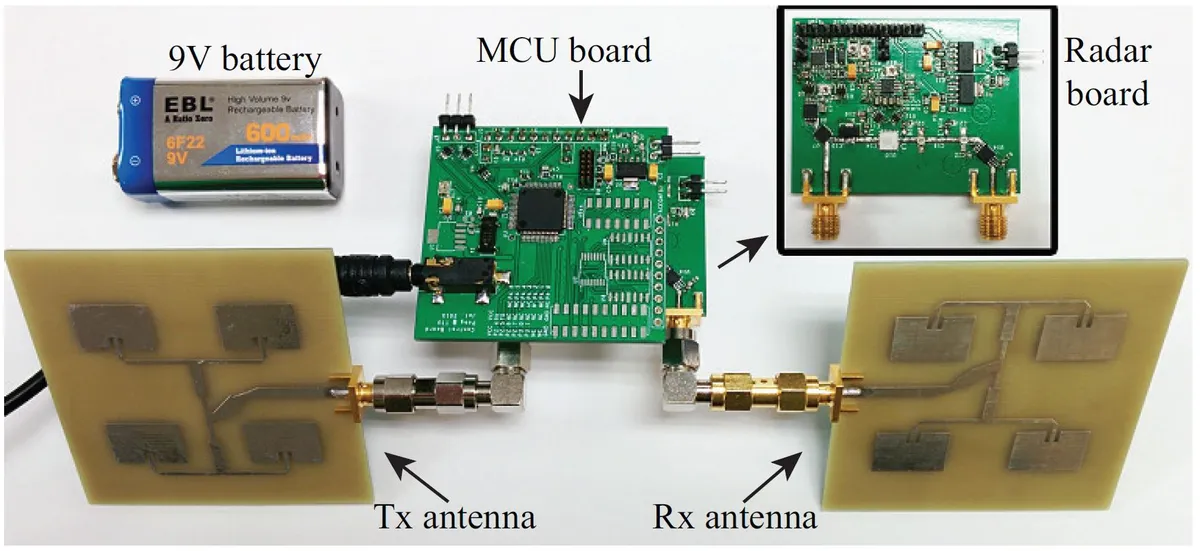
A palm-sized 5.8-GHz radar that works in two modes. In FMCW mode it measures range, so it can map and track people. In interferometry mode it holds a single frequency and picks up tiny motions such as breathing and heartbeat. An on-board microcontroller switches between the two, and both modes share the same RF parts and signal paths, which keeps the radar small and cheap.
I used it to locate people among parked cars, track walkers in a cluttered corridor, detect falls, and record the Doppler signatures of wind turbines.
- Frequency
- 5.8 GHz (C-band)
- Modes
- FMCW and interferometry, on one RF chain
- Size
- 50 × 60 × 20 mm, two stacked boards
- Controller
- TI MSP430
- Data capture
- A laptop sound card
Design
Low cost by sharing everything
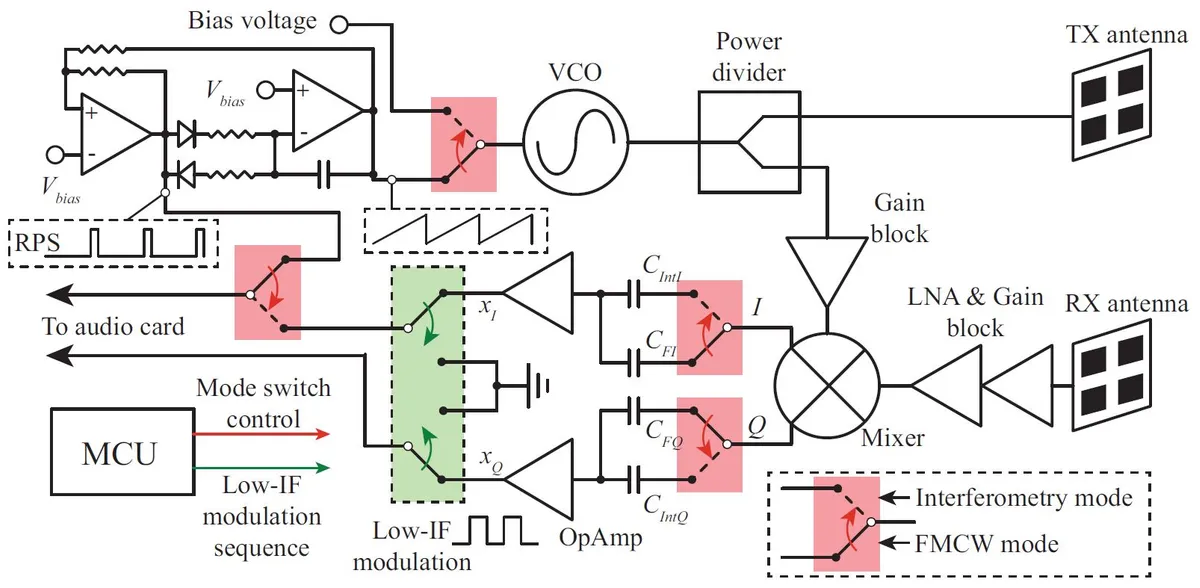
Fig. 2 shows the architecture. Both modes run through the same RF front end and baseband amplifiers, and the baseband signal is sampled by an ordinary laptop sound card instead of a dedicated data-acquisition board.
Interferometry mode: a low-IF trick for vital signs
Breathing and heartbeat produce baseband signals below a few hertz. A sound card's input filter blocks frequencies that low, so the radar shifts them up first: a programmable low-IF modulation moves the baseband signal to an intermediate frequency the sound card can pass. This also moves the signal away from the flicker noise that crowds the spectrum near DC. After sampling, envelope detection recovers the vital signs. In the paper I analyze the distortion that low-IF modulation introduces and how to get the best sensitivity from envelope detection.
FMCW mode: coherence without a PLL
A free-running VCO, driven by a sawtooth from a simple op-amp circuit, generates the frequency sweep. A free-running sweep is not locked to anything, so the radar also records a reference pulse sequence that is locked to the sawtooth. Sampling it alongside the beat signal marks the start of every chirp, which makes the FMCW measurements coherent.
Hardware
Two boards, two antenna options
The prototype in Fig. 1 is two PCBs stacked together. The top board carries the MSP430 microcontroller. The bottom board is the radar itself: the sawtooth and reference generator, the RF front end, and the baseband amplifiers. Depending on the experiment, it uses one of two patch-antenna arrays:
| Antenna | Gain | Half-power beamwidth | Trade-off |
|---|---|---|---|
| 2 × 2 patch array | 11.3 dB | 46° | Wider coverage |
| 4 × 4 patch array | 16.3 dB | 21.6° | Longer range, finer angular resolution |
Experiments
What the radar can do
Finding a person among parked cars
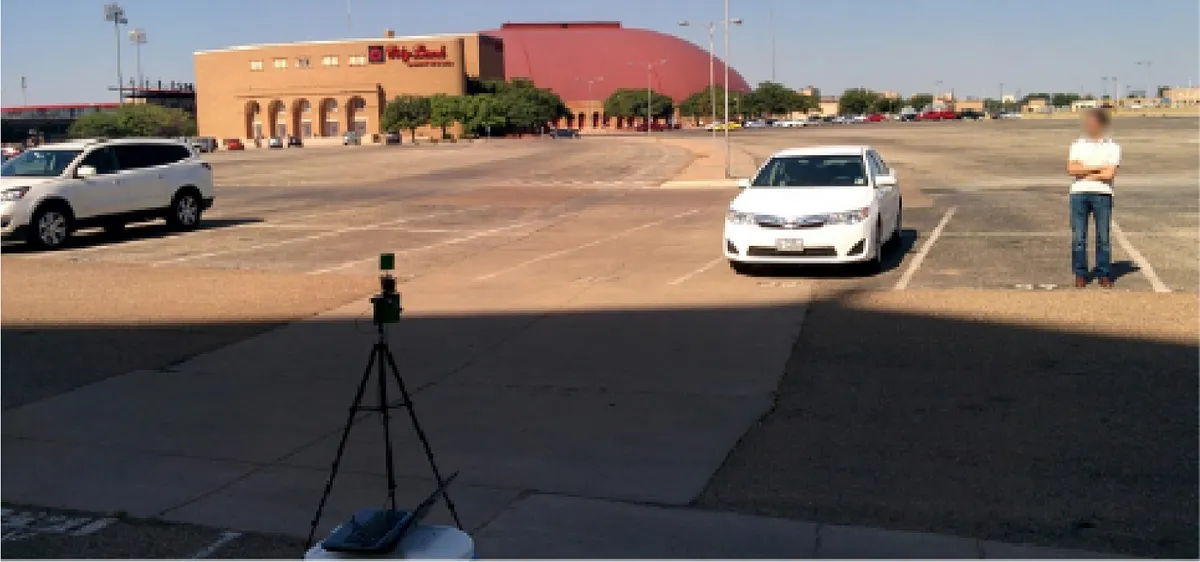
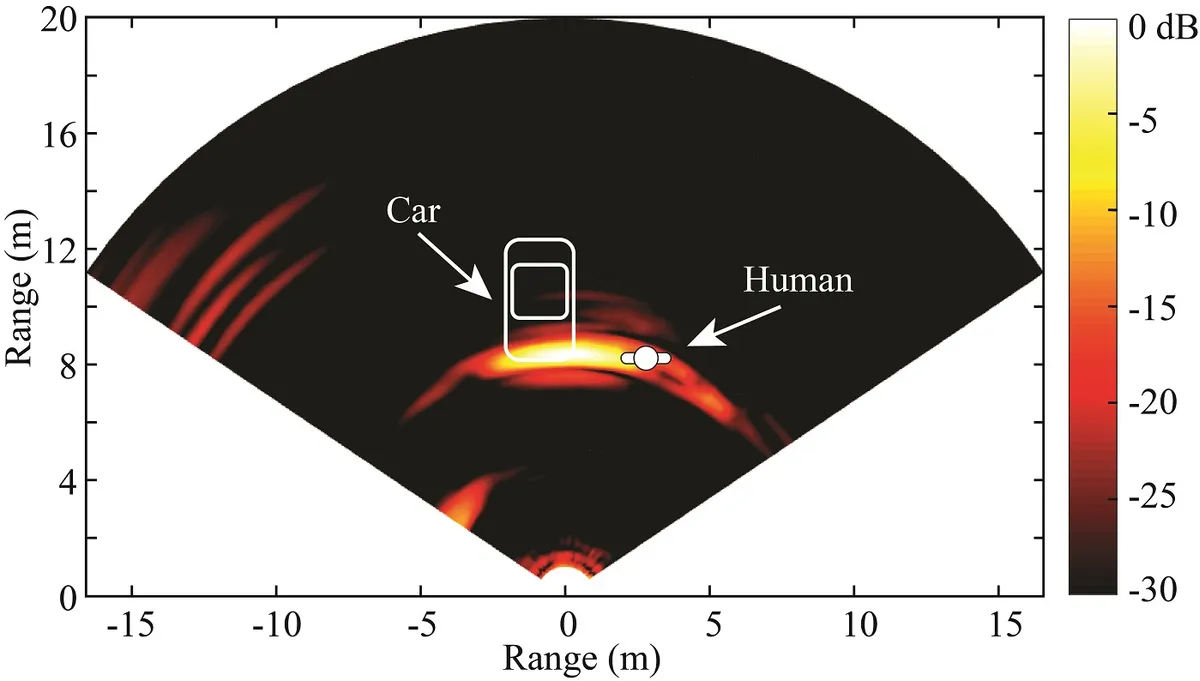
To build a 2-D map, I rotated the radar mechanically and recorded a range profile in each direction (Fig. 3). In the resulting map (Fig. 4), the strong echo at about 8 m is a car and a person standing next to it. They show up as one target because the 21.6° beam is too wide to separate them, and a portable radar cannot carry an antenna large enough for a much narrower beam. The echoes on the left are other parked cars.
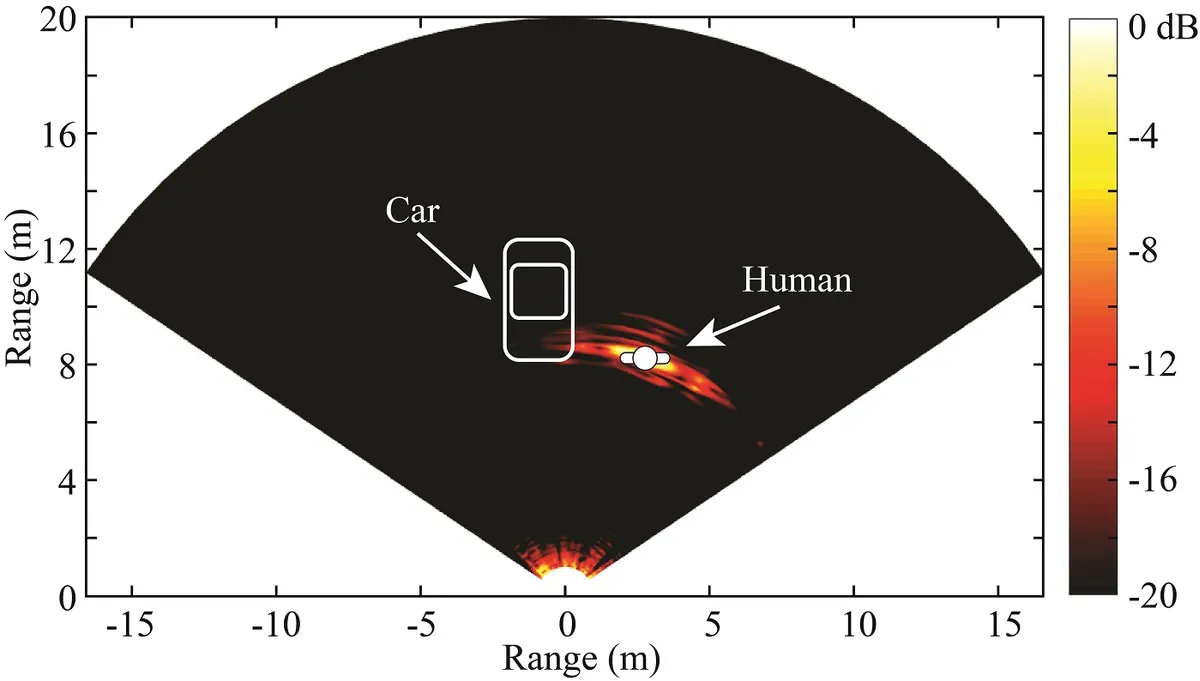
A person, however, is never perfectly still: breathing and small body movements make their echo fluctuate from scan to scan. Taking the standard deviation of repeated scans in each direction keeps the person and removes everything that does not move, including the parked car with its engine running (Fig. 5).
Tracking two people in a cluttered corridor
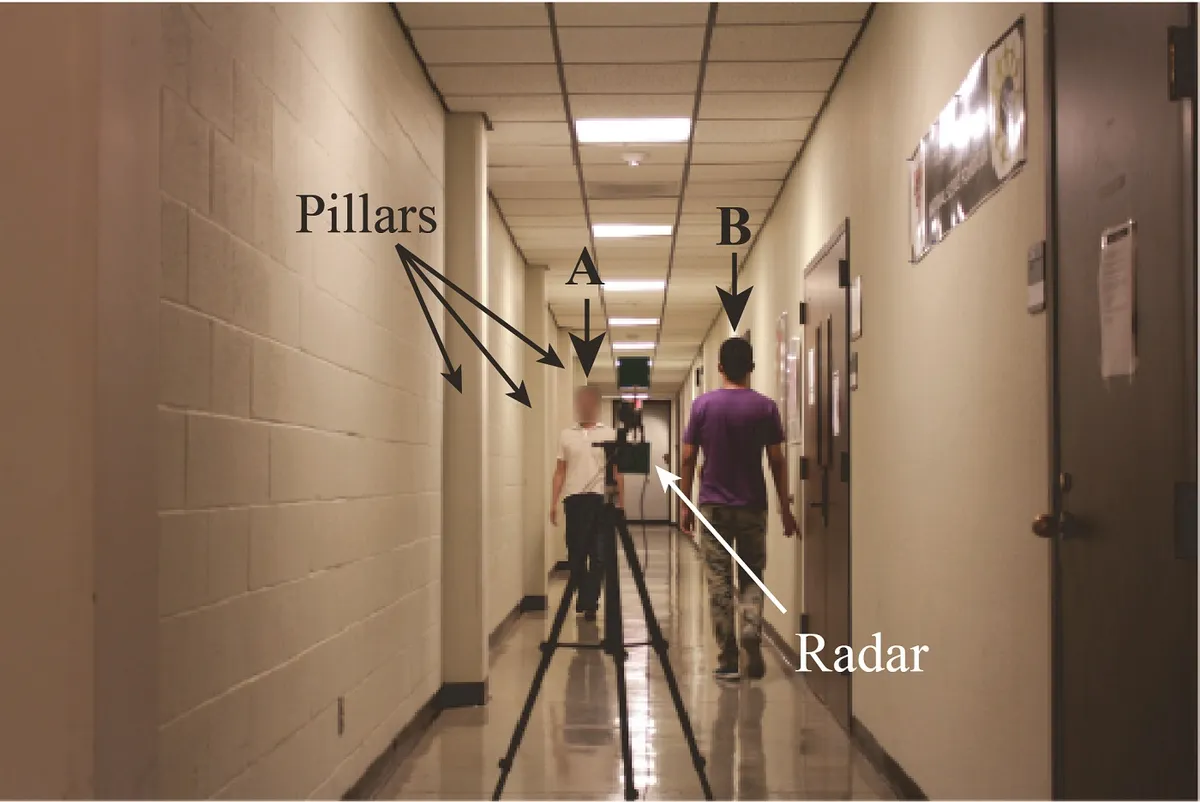
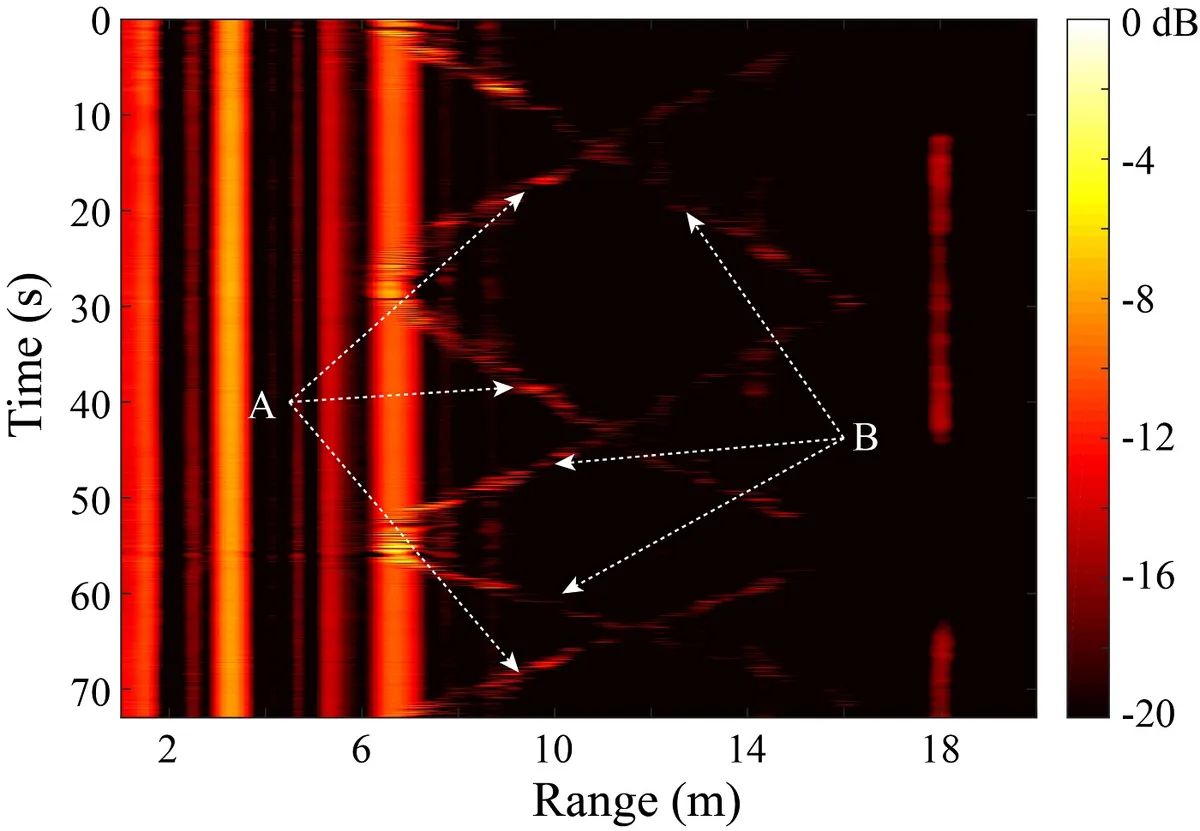
Two people walked in opposite directions in front of the radar, in a narrow corridor full of walls and pillars (Fig. 6). In the range profiles over the 73-second recording (Fig. 7), the strong vertical stripes are stationary clutter, and the two walkers appear as much fainter traces.
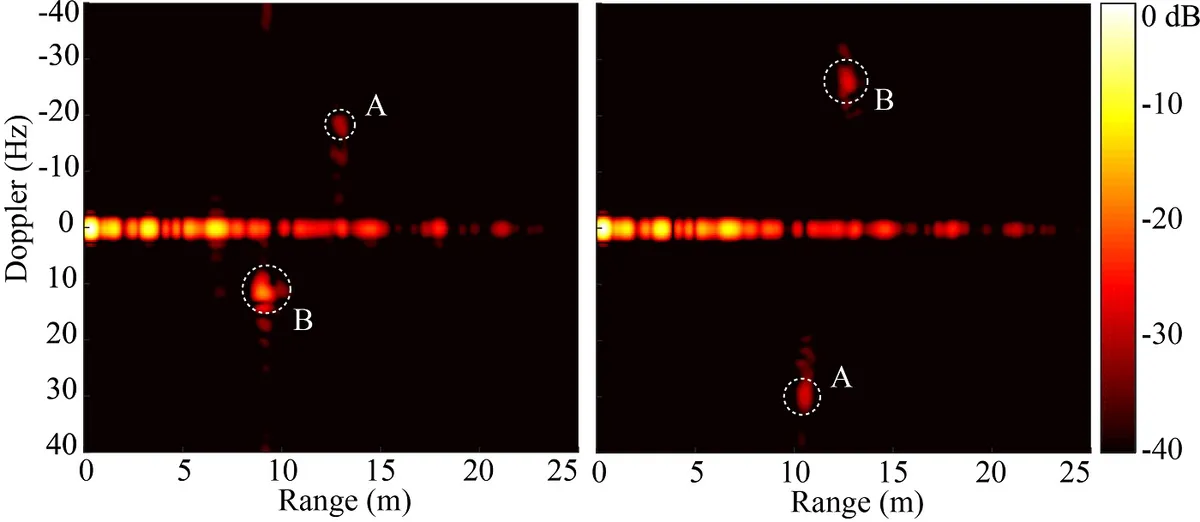
Adding Doppler to range separates them. In the range-Doppler frames (Fig. 8), each person appears as a distinct target that can be followed from frame to frame, which is the basis for short-range tracking in healthcare or driverless-vehicle applications.
Monitoring wind turbines
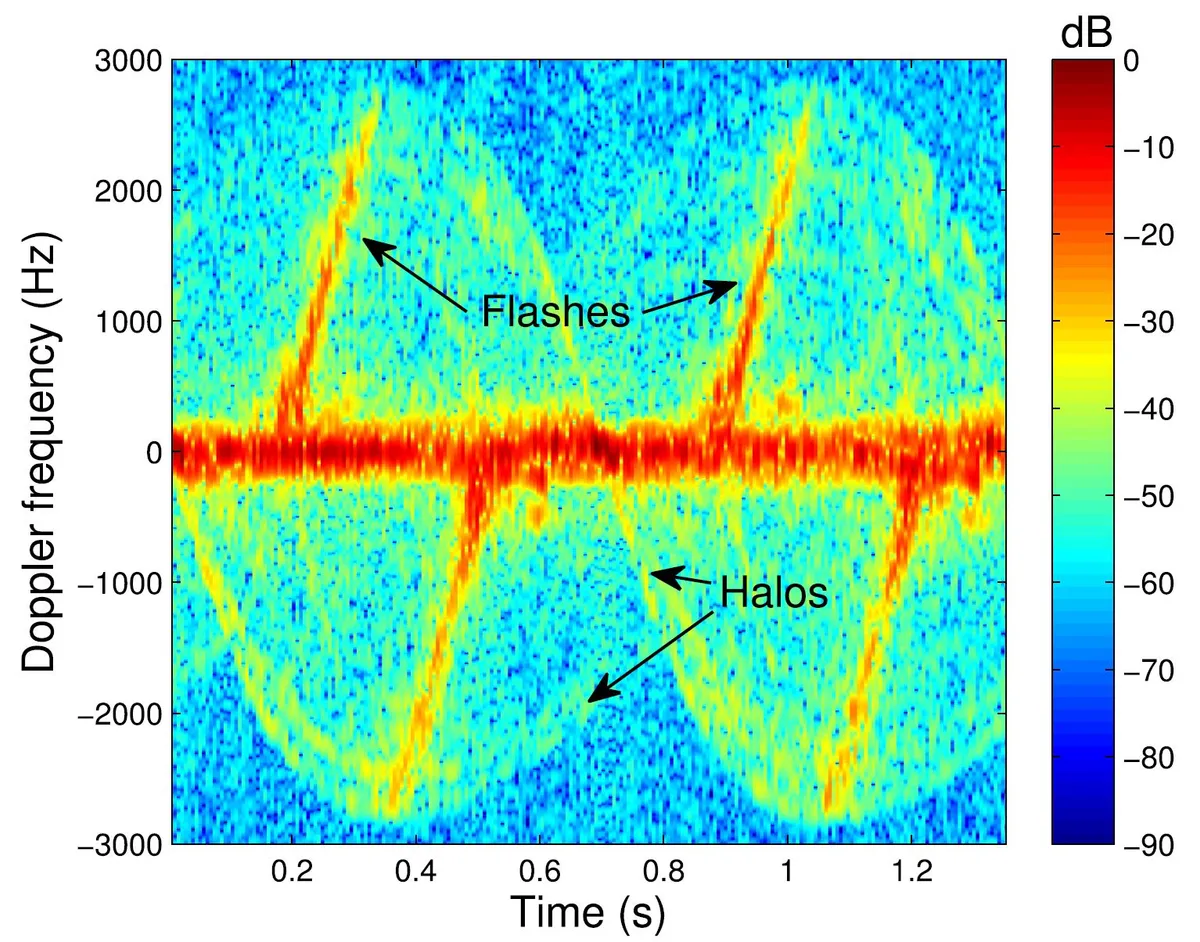
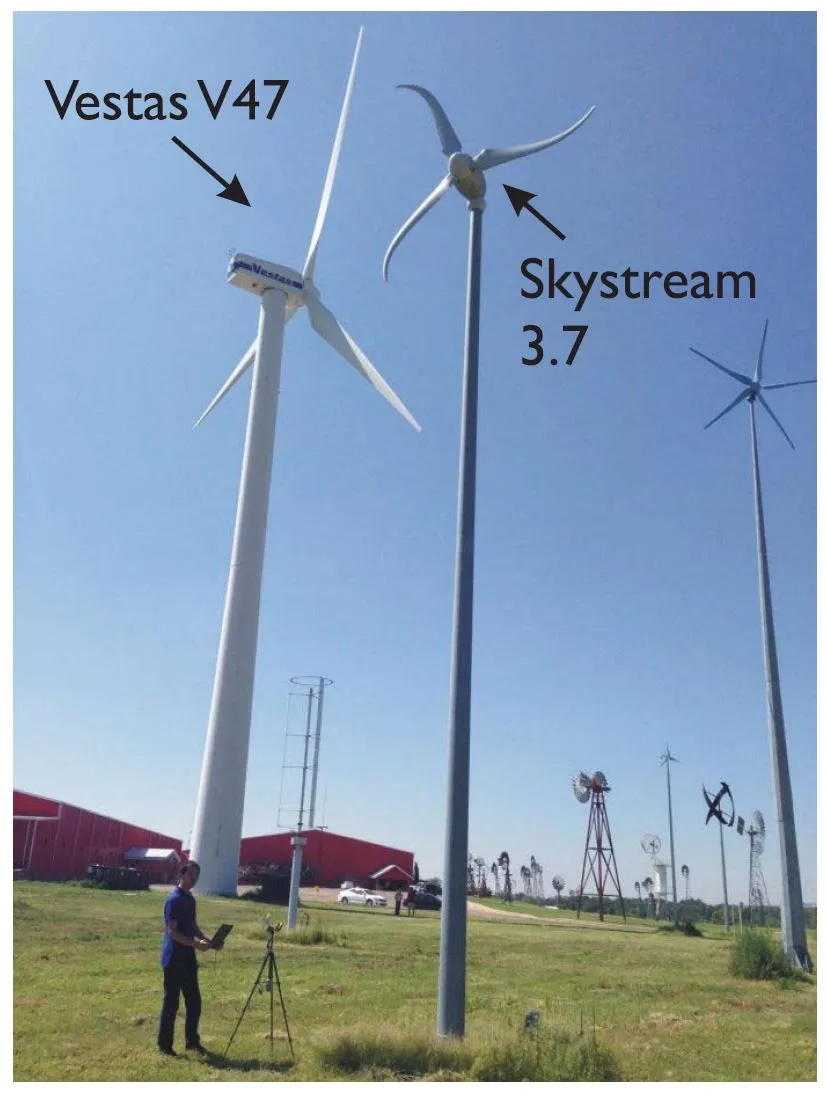
The American Wind Power Center in Lubbock, Texas, has wind turbines in many sizes, with different numbers of blades and with horizontal or vertical rotation axes. I aimed the radar at them (Fig. 10) and recorded their micro-Doppler signatures. Fig. 9 shows the spectrogram of a Vestas V47. Signatures like this can be used to monitor the structural health of the turbine.
Detecting falls
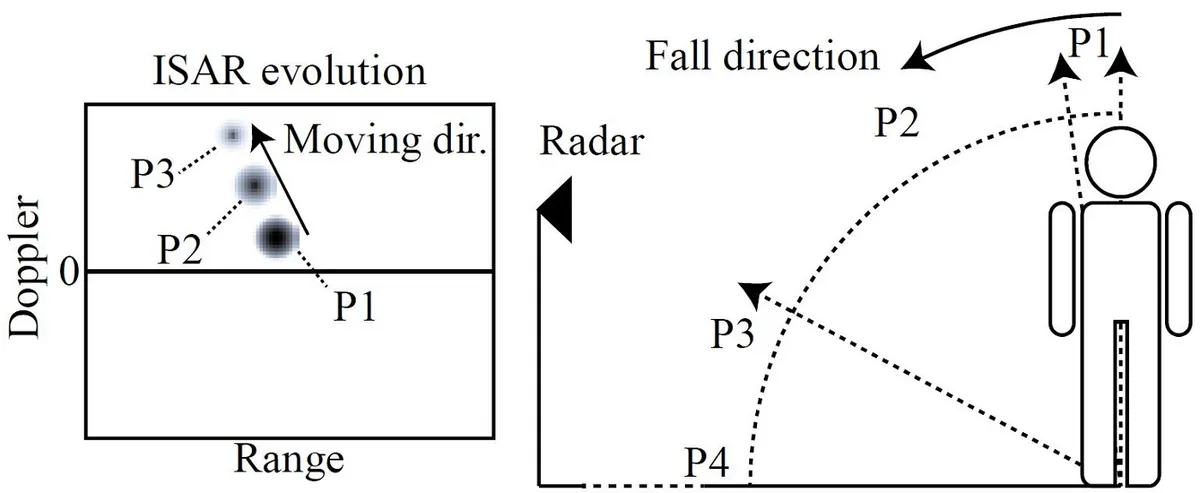
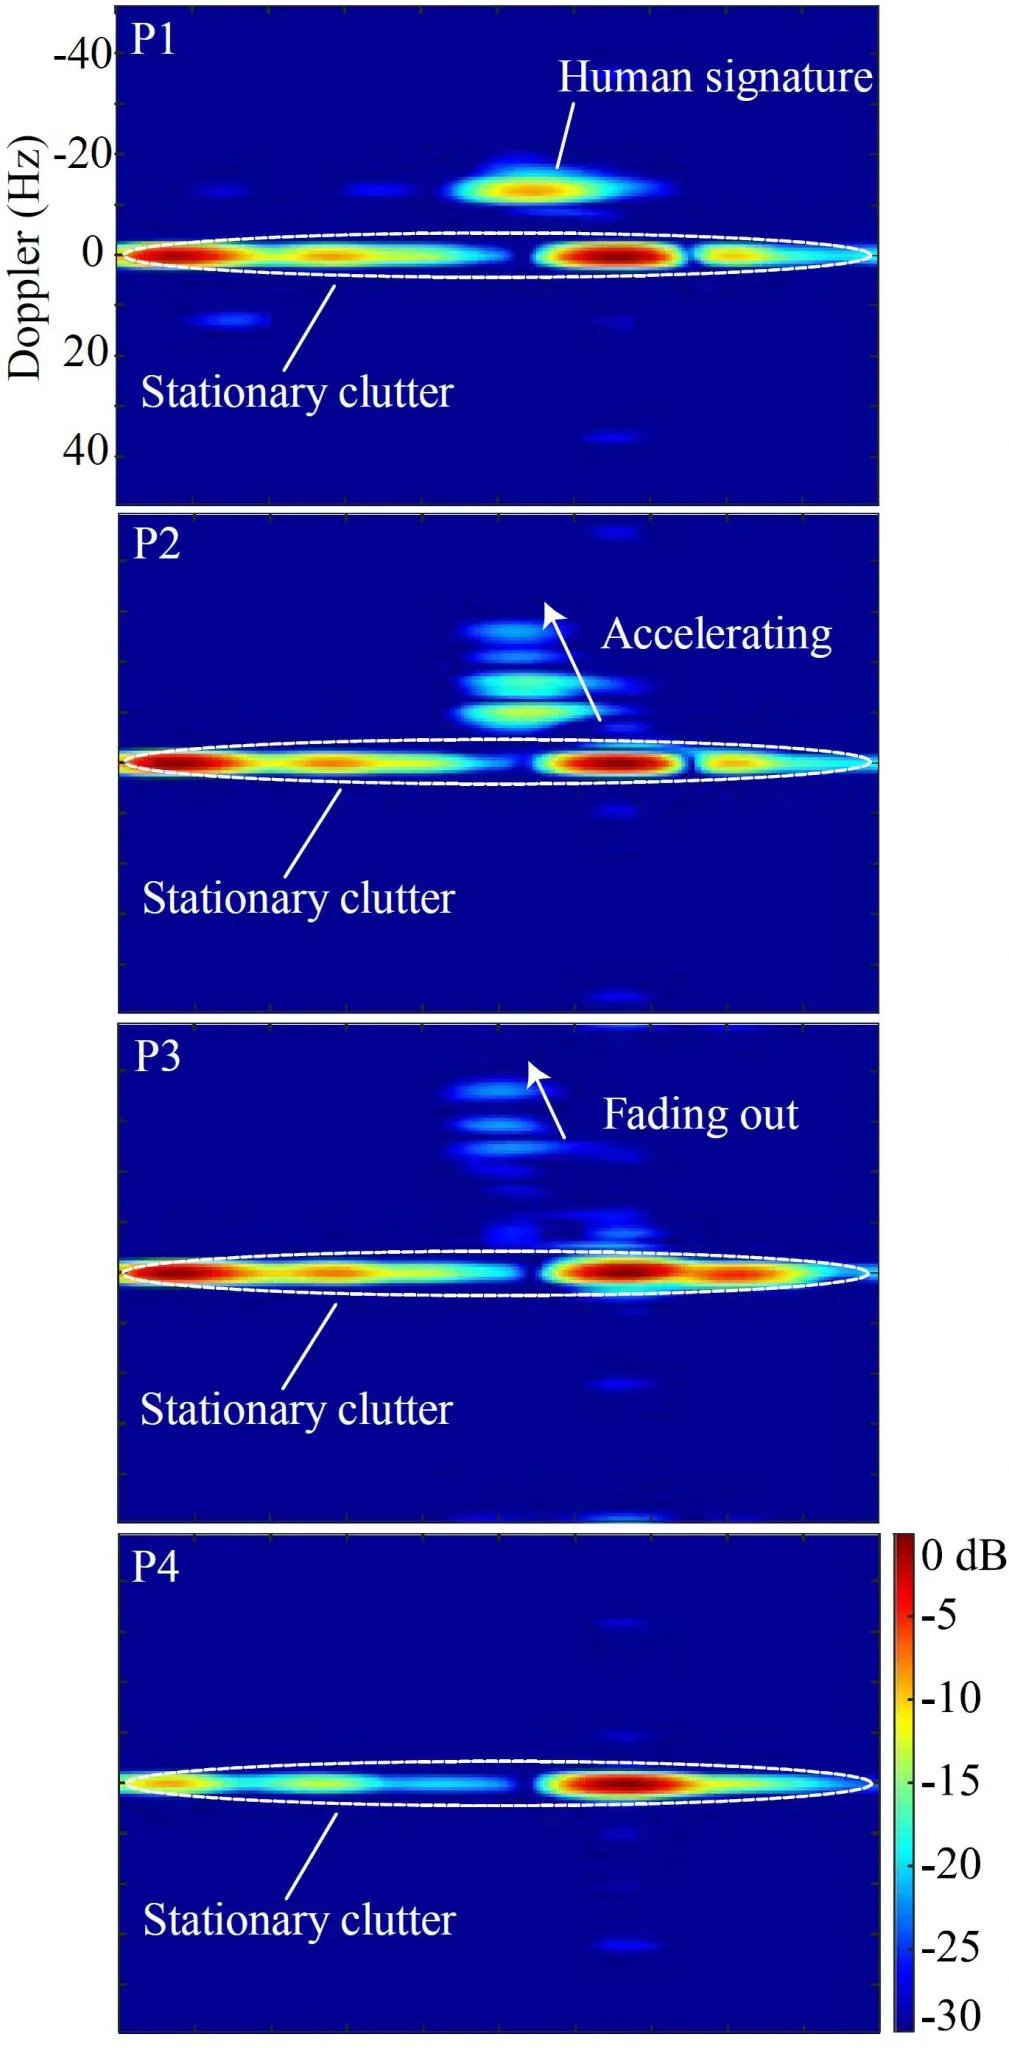
Falls are among the leading causes of fatal and non-fatal injuries in older adults. In this experiment a person fell toward the radar. The fall divides into four phases, each with its own pattern of speed, range, and radar cross section (Fig. 11). These phases appear clearly in the range-Doppler images (Fig. 12), which shows that an FMCW radar can detect falls from range-Doppler imaging in real time.
Publications
Where this work appeared
- A portable FMCW-interferometry radar with programmable low-IF architecture for localization, ISAR imaging and vital-sign trackingZ. Peng, J.-M. Muñoz-Ferreras, Y. Tang, R. Gómez-García, L. Ran, and C. LiJournalIEEE Transactions on Microwave Theory and Techniques, vol. 65, no. 4, pp. 1334–1344, Apr. 2017
- Short-range Doppler-radar signatures from industrial wind turbines: theory, simulations, and measurementsJ.-M. Muñoz-Ferreras, Z. Peng, Y. Tang, R. Gómez-García, D. Liang, and C. LiJournalIEEE Transactions on Instrumentation and Measurement, vol. 65, no. 9, pp. 2108–2119, Sep. 2016
- An FMCW radar sensor for human gesture recognition in the presence of multiple targetsZ. Peng, J.-M. Muñoz-Ferreras, C. Li, and R. Gómez-GarcíaConferenceIEEE International Microwave Bio-Conference (IMBioC), Göteborg, Sweden, May 2017
- Doppler-radar-based short-range acquisitions of time-frequency signatures from an industrial-type wind turbineJ.-M. Muñoz-Ferreras, Z. Peng, Y. Tang, R. Gómez-García, and C. LiConferenceIEEE Wireless Sensors and Sensor Networks (WiSNet), Phoenix, AZ, Jan. 2017
- FMCW radar fall detection based on ISAR processing utilizing the properties of RCS, range, and DopplerZ. Peng, J.-M. Muñoz-Ferreras, R. Gómez-García, and C. LiConferenceIEEE International Microwave Symposium (IMS), San Francisco, CA, May 2016